PhD candidate · aid-lab · The University of Sydney

Yihao Dong

I build haptic interfaces that let people with vision impairment feel the shape of the world around them.

“touch”, in Braille

01 — News

News

  1. I presented TactDeform at CHI ’26 in Barcelona, both the paper and the interactive demo. Thank you to everyone who stopped by for a chat.

  2. I have two papers accepted at CHI ’26 in Barcelona! I’m looking forward to presenting TactDeform and SRL Proxemics.

  3. I was awarded the Best Early PhD Project at the 2025 University of Sydney School of Computer Science Research Showcase.

  4. I started as an Associate Lecturer (PhD Teaching Fellow), teaching COMP9001 and COMP9123. More on my teaching.

  5. Our paper Juggling Extra Limbs received an Honorable Mention at CHI ’25 in Yokohama, placing it in the top 5% of submissions.

  6. My paper Just Before Touch was published at Augmented Humans (AHs ’25). Try the demo.

  7. I started my PhD in the aid-lab at the University of Sydney, supervised by Associate Professor Anusha Withana.

02 — Hello

Yihao Dong, standing against a plain grey background in a dark jacket and glasses.
Sydney, 2026

I make interfaces you can feel.

I'm a PhD candidate in the aid-lab at the University of Sydney, working with Associate Professor Anusha Withana. My research asks whether touch can carry the spatial information that sight usually does: I design wearable haptic interfaces so that people with vision impairment can perceive the shape of the space around them, and I run the studies that find out whether it works.

Before the PhD I finished a double degree in Advanced Computing (Honours Class I) and Commerce, which is why I care as much about whether something is usable and worth building as about whether it works on the bench.

I also teach. Since late 2025 I've been an Associate Lecturer in the School of Computer Science, teaching programming, algorithms and mobile computing to postgraduate students.

03 — Selected work

Two things you can try

Selected work

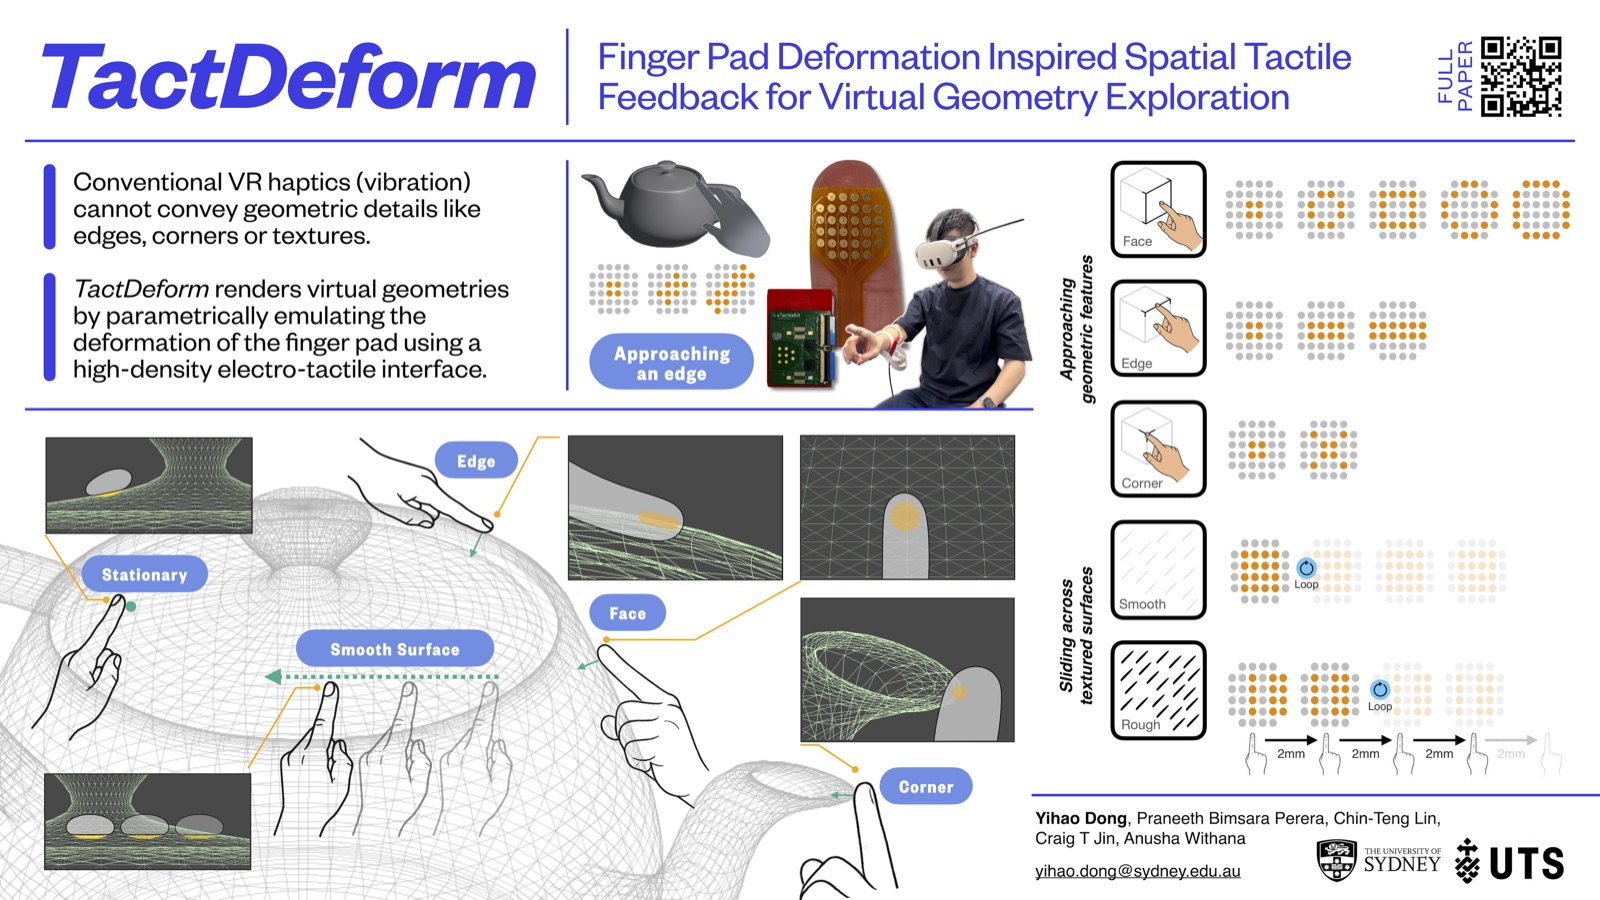
TactDeform poster: a finger exploring a wireframe teapot while an electrode grid renders faces, edges and corners.

CHI ’26 · first author

TactDeform

Finger-pad deformation as a design language for spatial tactile feedback.

Vibration alone cannot convey edges, corners or texture. TactDeform drives a high-density electro-tactile array on the finger pad to emulate how skin deforms against virtual geometry.

Try the demo
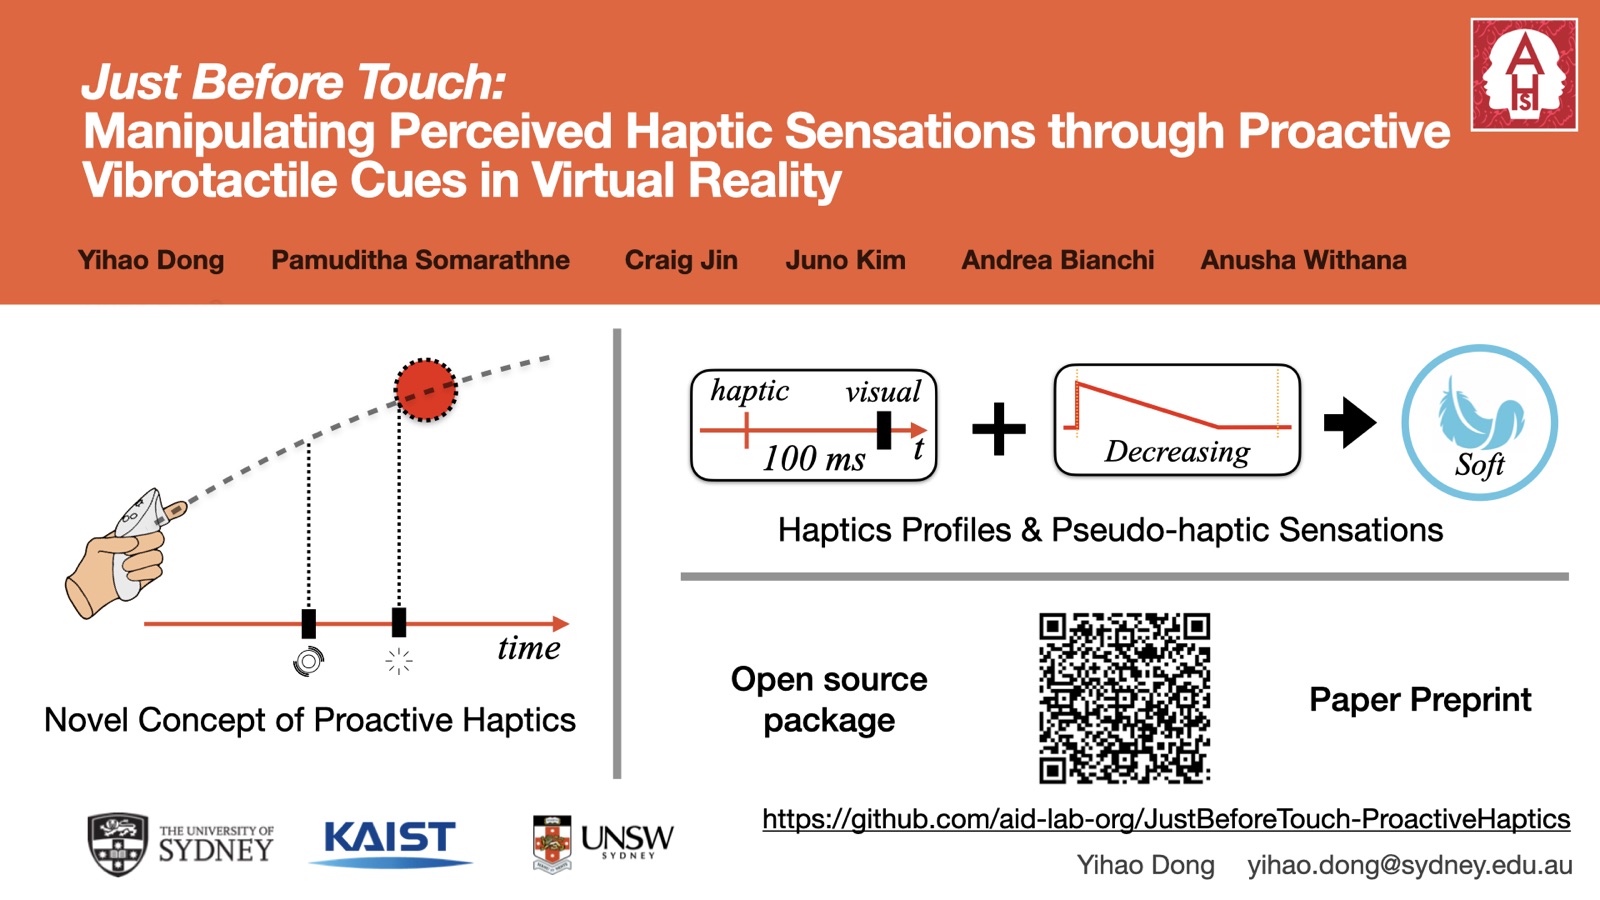
Just Before Touch poster: a controller approaching a ball on a timeline, with a haptic cue 100 milliseconds before visual contact.

AHs ’25 · first author

Just Before Touch

Proactive haptics: a cue that arrives before the contact does.

A vibrotactile pulse fired about 100 ms before visual contact changes what a virtual touch feels like, which opens a cheap way to shape perceived softness in VR.

Try the demo

04 — Recent papers

Recent papers

05 — Reach

Working on haptics, accessibility or XR? Say hello.